Check the process first
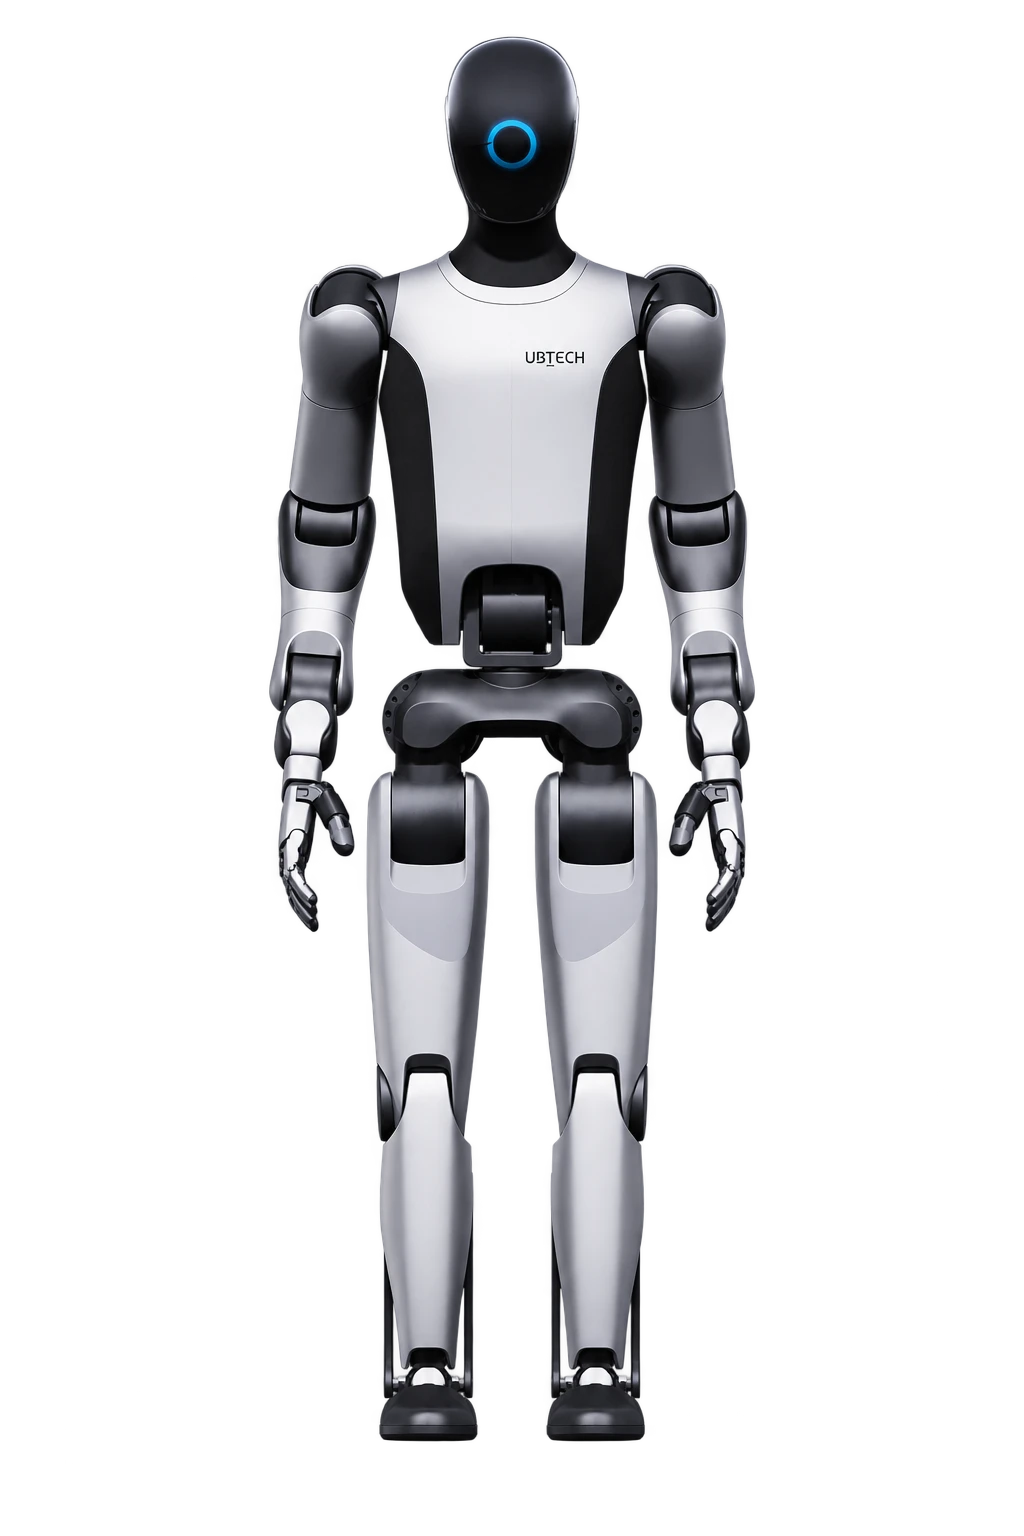
Choose one part and workstation. Record mass, shape, position tolerance and grasp points. Require the complete sequence: detection, pickup, movement, placement and return. Rated payload proves neither the sequence nor cycle time. Track successful attempts, damage, retries and operator assistance. Check machine access, signal exchange and stopping procedures. Walker S2 is a candidate for industrial pilot discussions; confirm application scope and availability. This is not a ready replacement for any workstation operator.
Prepare data for the trial
- Measure task duration and frequency.
- Record requirements for the environment, people and load.
- Agree an acceptable intervention level and acceptance criteria.
- Compare the trial result with your current workflow.