Model names do not define control access
The same body may ship in demonstration or research editions. Compare sensor reads, joint commands, whole-body control and communication rates. Request documentation for the ordered configuration. EDU has no universal meaning across manufacturers. Confirm custom locomotion-policy access explicitly if your project needs it.
Check the development environment
An interface list is insufficient. Run a sample, receive data and execute a simple controlled motion. Check OS, library and firmware compatibility. For simulation request geometry, mass, joint limits and actuator models. A URDF file alone does not provide dynamic simulation or ready sim-to-real transfer.
Match hands and sensors to experiments
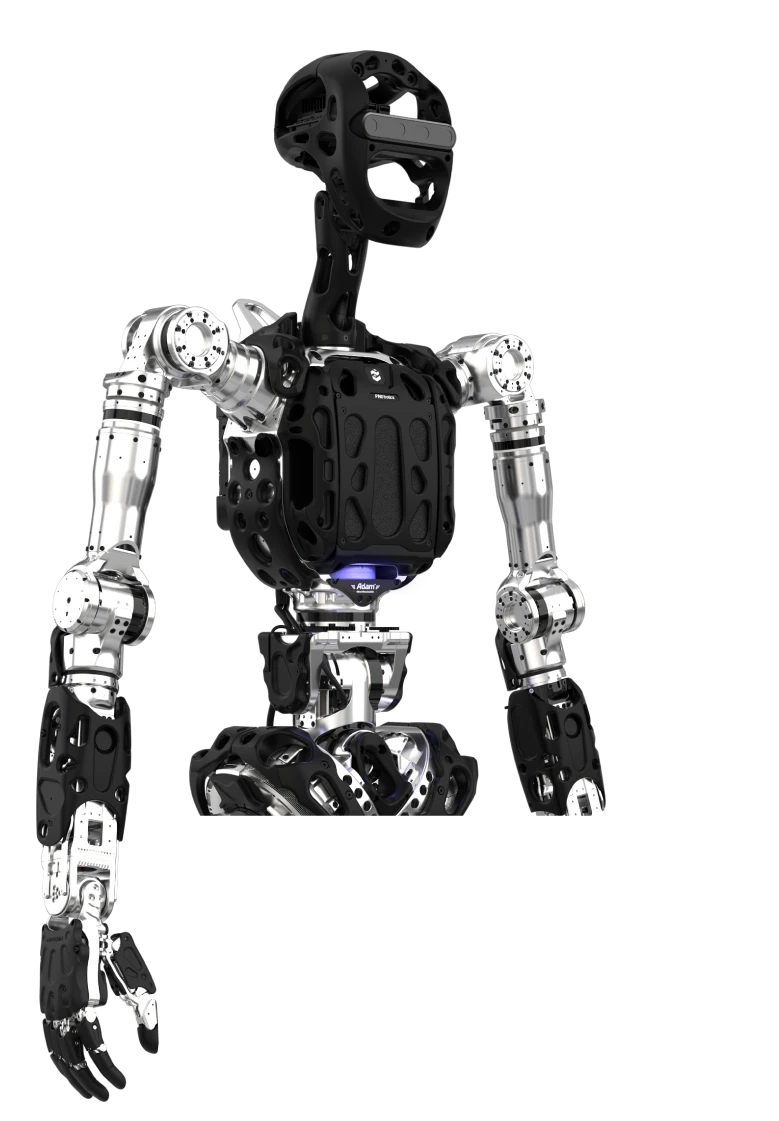
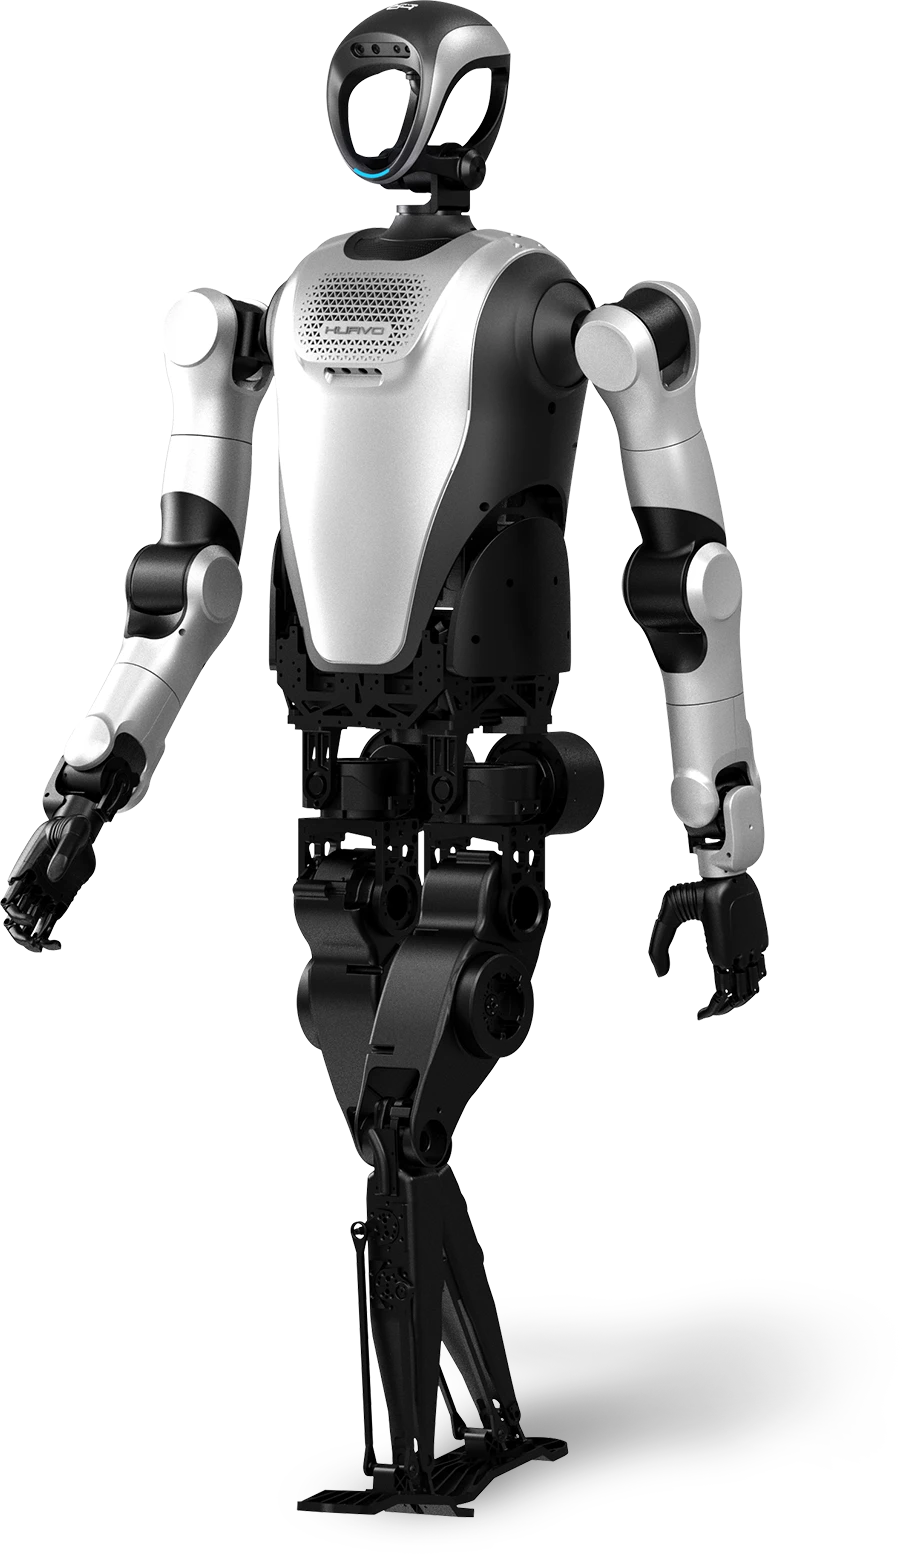
More degrees of freedom do not always help research goals. A simple gripper may improve repeatability; dexterous hands serve specific manipulation studies. Check tactile data, cameras and calibration. Distinguish active and passive joints, body and hand axes. Adam and T800 specifications vary by edition; compare exact configurations.
Plan the laboratory and continuity
Budget for workspace, manufacturer-required protective equipment, batteries, charging, transport and training. Define student procedures and permission to install custom software. Preserve a working configuration before control changes. Clarify research damage, warranty and authorised module replacement. Confirm publication rights for results, data and code in contracts and licences.